Rotational Kinematics

Introduction

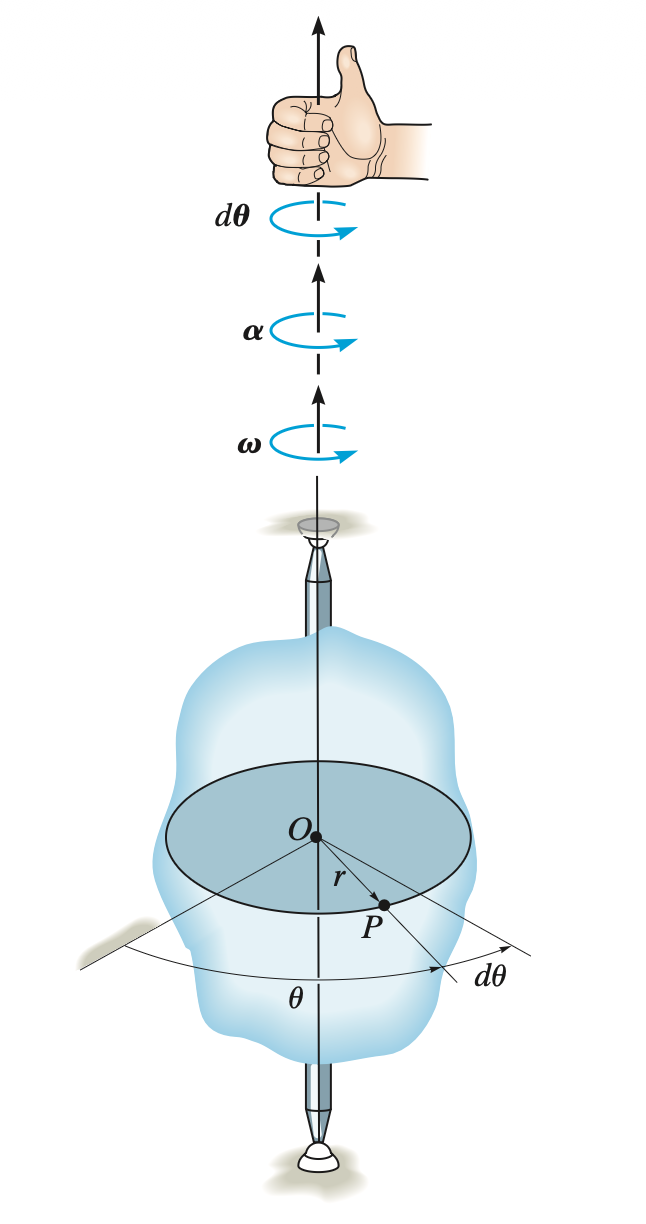
Rotational kinematics describes the motion of rigid bodies rotating about a fixed axis. It relates angular position, velocity, and acceleration without considering the forces or moments causing the motion. These relationships are directly analogous to linear kinematics.

image

Angular Position, Velocity, and Acceleration

Angular position ( θ ) (\theta) is measured in r a d rad , and θ = s r \theta = \frac{s}{r} .

Angular velocity ( ω ) (\omega) is measured in r a d / s rad/s , and ω = d θ d t \omega = \frac{d\theta}{dt}

v t = ω r v_{t} = \omega r

Angular acceleration ( α ) (\alpha) is measured in r a d / s 2 rad/s^{2} , and α = d ω d t \alpha = \frac{d\omega}{dt}

a t = α r a_{t} = \alpha r and a n = ω 2 r a_{n} = \omega^{2}r

Constant Angular Acceleration

The equations are analogous to the constant-acceleration equations for linear motion:

θ = θ 0 + ω 0 t + 1 2 α t 2 \theta = \theta_{0} + \omega_{0}t + \frac{1}{2}\alpha t^{2}

ω = ω 0 + α t \omega = \omega_{0} + \alpha t

ω 2 = ω 0 2 + 2 α ( θ − θ 0 ) \omega^{2} = \omega_{0}^{2} + 2\alpha(\theta - \theta_{0})

Rolling Without Slipping

image

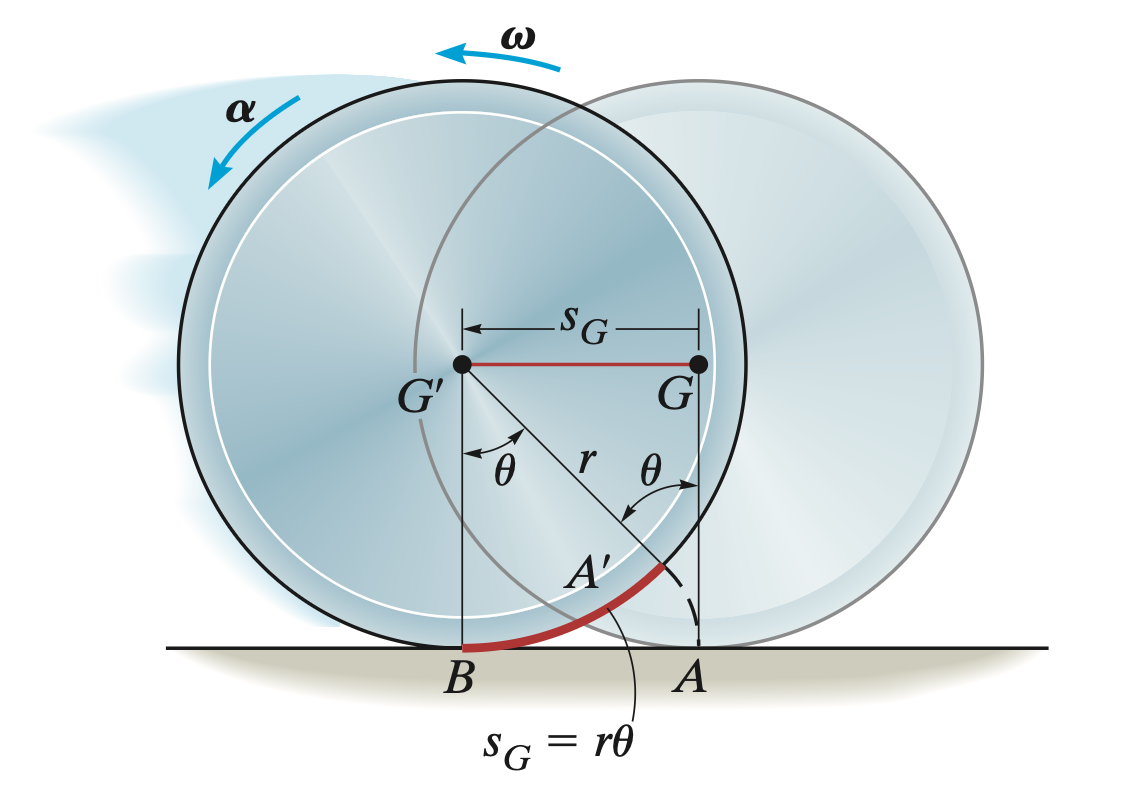
For pure rolling,

s G = r θ s_{G} = r\theta

v G = r ω v_{G} = r\omega

a G = r α a_{G} = r\alpha

Varying Angular Acceleration

When α \alpha is changing over time, calculus is required:

α ( t ) = d ω d t \alpha(t) = \frac{d\omega}{dt} ⇒ \Rightarrow ω = ∫ α ( t ) d t \omega = \int_{}^{}\alpha(t)dt

ω ( t ) = d θ d t \omega(t) = \frac{d\theta}{dt}^{} ⇒ \Rightarrow θ = ∫ ω ( t ) d t \theta = \int_{}^{}\omega(t)dt

When α = f ( θ ) \alpha = f(\theta) , use α d θ = ω d ω \alpha d\theta = \omega d\omega : ∫ θ 0 θ α ( θ ) d θ = ∫ ω 0 ω ω d ω \int_{\theta_{0}}^{\theta}\alpha(\theta)d\theta = \int_{\omega_{0}}^{\omega}\omega d\omega

Example 1:
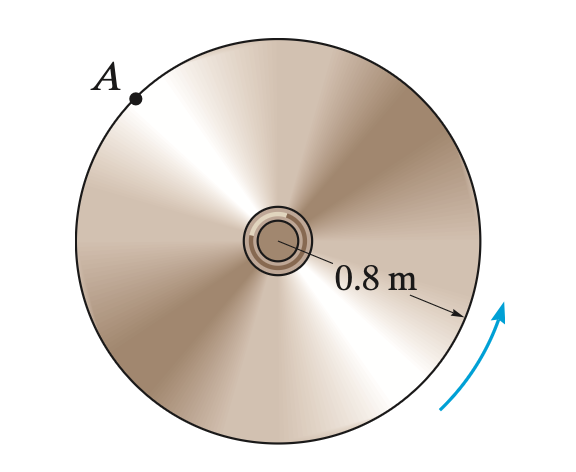
Find the magnitude of velocity and acceleration of point A on the disk when t = 0.5 s if ω = ( 5 t 2 + 2 ) r a d / s \omega = (5t^{2} + 2)\ rad/s .

image

α = d ω d t = 10 t r a d / s 2 \alpha = \frac{d\omega}{dt} = 10t\ rad/s^{2}

At t = 0.5 s:

ω = 5 ( 0.5 ) 2 + 2 = 3.25 r a d / s \omega = 5(0.5)^{2} + 2 = 3.25\ rad/s

α = 10 ( 0.5 ) = 5 r a d / s 2 \alpha = 10(0.5) = 5\ rad/s^{2}

v t = ω r = ( 3.25 r a d / s ) ( 0.8 m ) = 2.6 m / s v_{t} = \omega r = (3.25\ rad/s)(0.8\ m) = 2.6\ m/s\ \ \ \ ← \leftarrow ans.

a t = α r = ( 5 r a d / s 2 ) ( 0.8 m ) = 4 m / s 2 a_{t} = \alpha r = (5\ rad/s^{2})(0.8\ m) = 4\ m/s^{2}

a n = ω 2 r = ( 3.25 r a d / s ) 2 ( 0.8 m ) = 8.45 m / s 2 a_{n} = \omega^{2}r = (3.25\ rad/s)^{2}(0.8\ m) = 8.45\ m/s^{2}

a = a t 2 + a n 2 = 4 2 + 8.45 2 = 9.35 m / s 2 a = \sqrt{a_t^2 + a_n^2} = \sqrt{4^2 + 8.45^2} = 9.35\,m/s^2 ← \leftarrow ans.

Example 2:
Find the number of revolutions a wheel must undergo to acquire a clockwise angular velocity of 15 rad/s with initial angular velocity of 10 rad/s and constant angular acceleration of 3 rad/s2.

ω 2 = ω 0 2 + 2 α ( θ − θ 0 ) \omega^{2} = \omega_{0}^{2} + 2\alpha(\theta - \theta_{0})

( 15 r a d / s ) 2 = ( 10 r a d / s ) 2 + 2 ( 3 r a d / s 2 ) ( θ ) ⇒ θ = 20.83 r a d (15\ rad/s)^{2} = (10\ rad/s)^{2} + 2(3\ rad/s^{2})(\theta)\ \ \Rightarrow \ \ \theta = 20.83\ rad

( 20.83 r a d ) ( 1 r e v o l u t i o n 2 π r a d ) = 3.32 r e v o l u t i o n s (20.83\ rad)(\frac{1\ revolution}{2\pi\ rad}) = 3.32\ revolutions

Example 3:
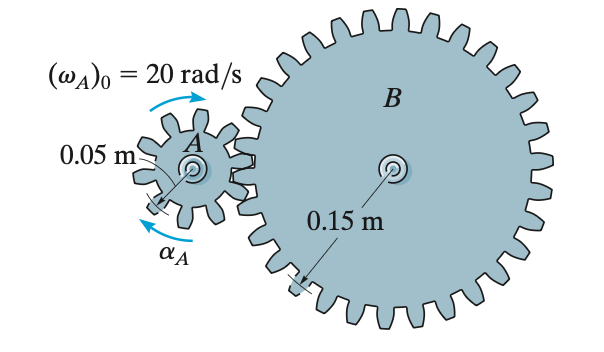
Find: Angular velocity of gear B when t = 2 s if gear A has an angular acceleration of (4t3) rad/s2 and the gear is initially turning at 20 rad/s.

image

Find angular velocity of gear A:

ω = ∫ α ( t ) d t = ω O + ∫ 0 2 4 t 3 d t = 20 + 16 = 36 r a d / s \omega = \int_{}^{}\alpha(t)dt = \omega_{O} + \int_{0}^{2}4t^{3}dt = 20 + 16 = 36\ rad/s

Since the gears roll without slipping:

v A = v B v_{A} = v_{B}

r A ω A = r B ω B r_{A}\omega_{A} = r_{B}\omega_{B}

( 0.05 m ) ( 36 r a d / s ) = ( 0.15 m ) ( ω B ) (0.05\ m)(36\ rad/s) = (0.15\ m)(\omega_{B})

ω B = 12 r a d / s \omega_{B} = 12\ rad/s