Relative Velocity and Acceleration of Rigid Bodies
Introduction
All points on a rigid body maintain a constant distance from one another. Therefore, the motion of any point can be determined from the motion of another point using the body’s angular velocity and angular acceleration.
Relative Velocity
For any two points A and B:
: translational component
: rotational component
points from A to B
For planar motion, ()
Cross Products:
Reversing the order changes the sign.
Instantaneous Center of Zero Velocity
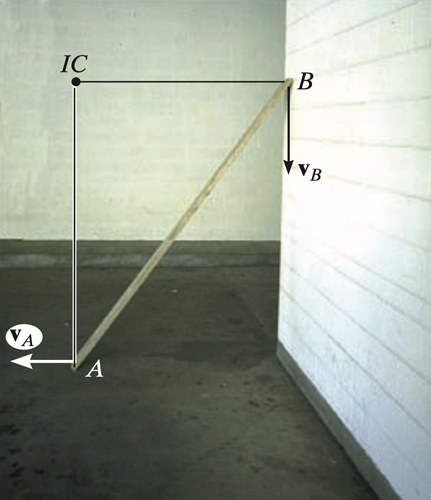
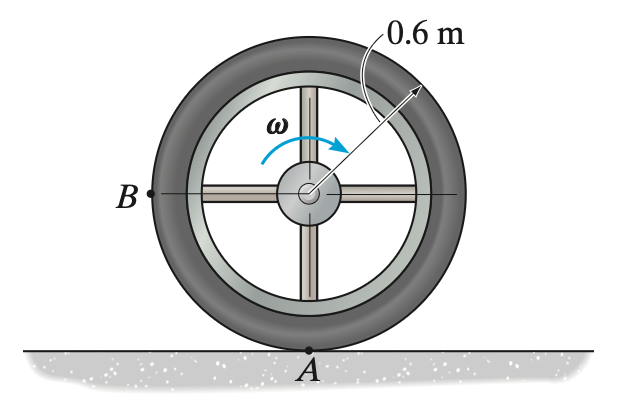
The instantaneous center (IC) is the point on (or outside) the body with zero velocity at an instant. An example is where a rolling bicycle wheel or car tire meets the ground.
The IC is applicable only to general plane motion, changes location with time, may lie outside the body, and is used to determine velocity only. If the IC is known, , where r is measured from the IC.
To find the IC, draw the known velocity directions and construct lines perpendicular to each velocity. The intersection of these lines is the IC. Compute and find any other velocity using .
Relative Acceleration
Acceleration has three terms (translational, tangential, and normal):
For planar motion,
To find acceleration , find the translational component , find and , compute the tangential and normal terms, then sum all components.
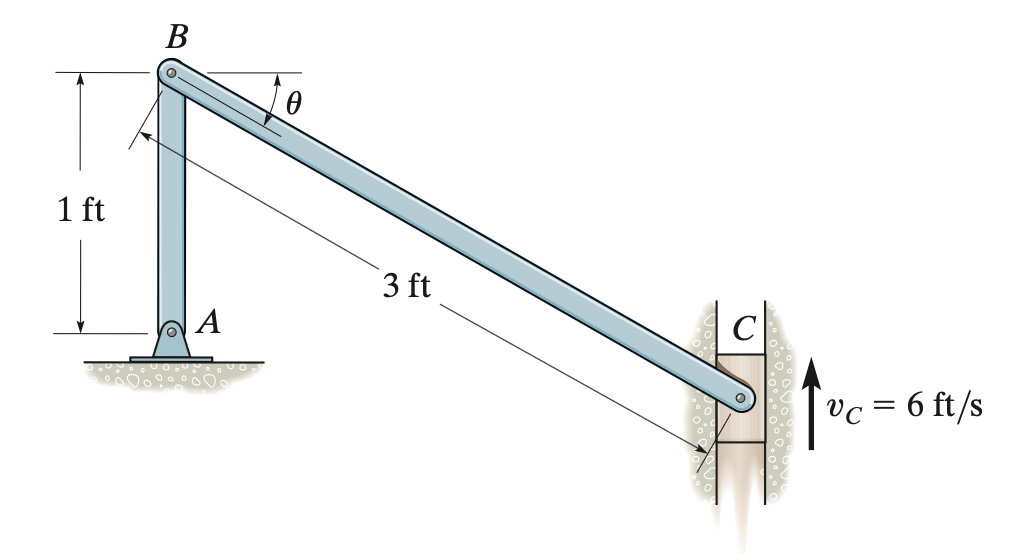
Example 1:
Find the angular velocity of link BC if
(horizontal) since AB is vertical
, , and
Relative velocity equation:
Distributing the cross product:
Combining i and j terms:
Therefore,
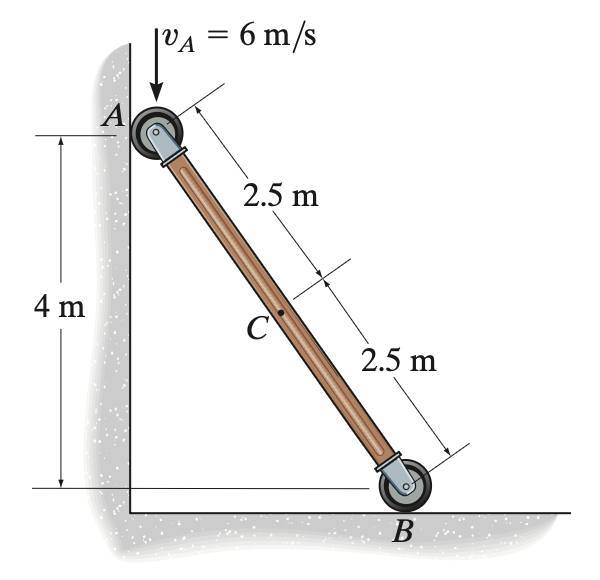
Example 2:
Find: Angular velocity of the rod and the velocity of point C.
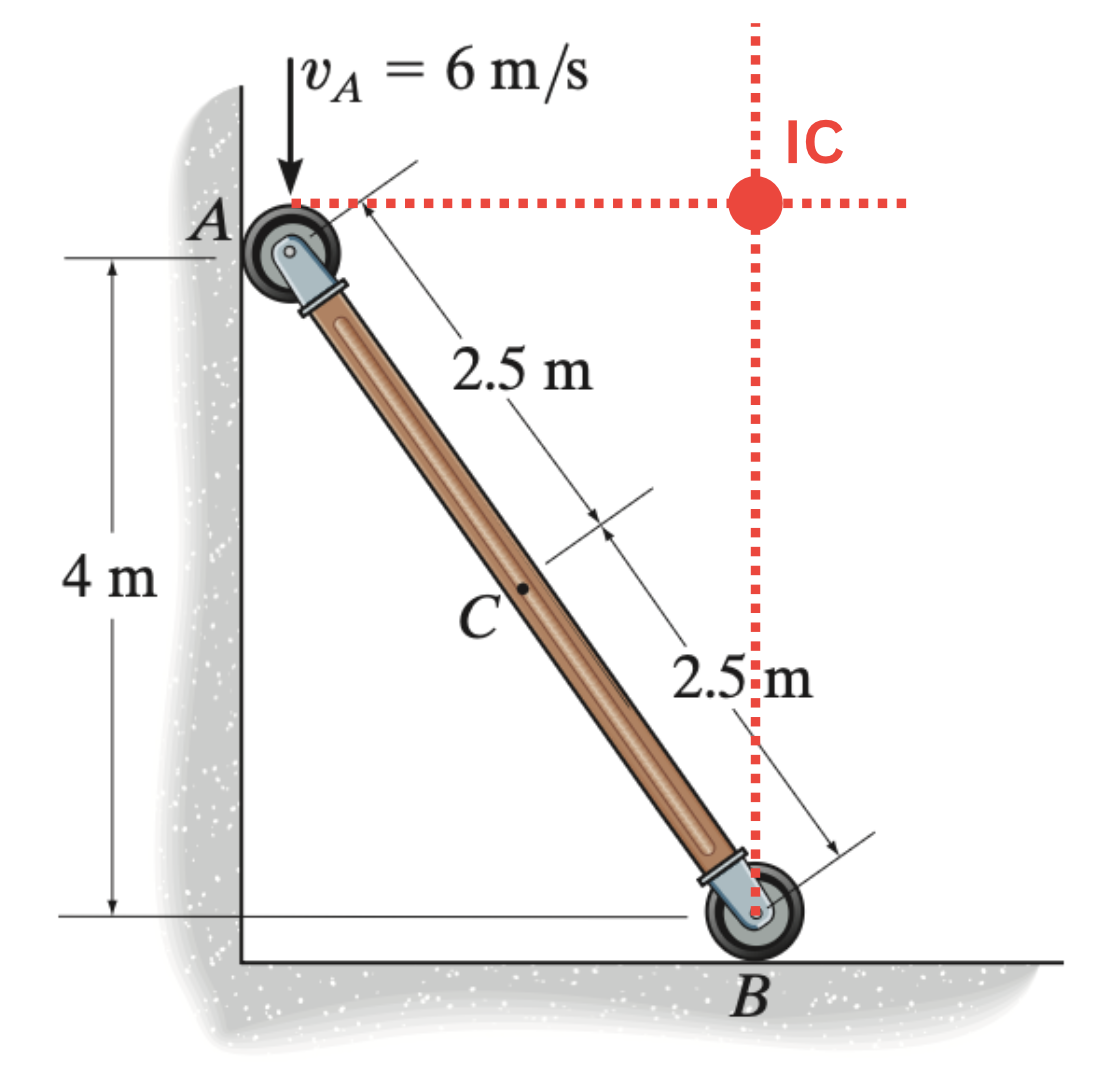
1) Locate the IC (intersection of the lines perpendicular to and )
2) Distance from A to IC (using the right triangle):
3)
4)
Example 3:
Find the magnitude of velocity at point B if .
Point A is the instantaneous center of velocity of the wheel, so